

However precisely a self-driving system reads the road and plans its route, that decision cannot be carried out safely unless the car knows its own grip, braking capacity, and steering capability. Dongfeng argues that intelligent driving and the chassis need to exchange information about each other's state and limits, coordinating propulsion, braking, steering, and suspension as a single motion. What used to be a set of limbs taking orders is becoming a cerebellum, judging what the car can physically do.
By Sang Min Han _ han@autoelectronics.co.kr
한글로보기
A speed bump appears ahead. A conventional chassis waits until the wheel hits it, lets the body jolt, then adjusts the dampers. Dongfeng's intelligent chassis reads the road surface with a camera first, and changes the ride height and damper state before the wheels reach the bump.
Wet roads work the same way. The system doesn't wait for the tires to slip before adjusting tractive and braking force. It estimates the surface type and friction coefficient ahead, combines that with vehicle load, grade, speed, and tire condition, and pre-distributes force across the front and rear axles. If the wheels behave differently than expected, it revises its estimate on the fly.
But smoothing out a speed bump or cutting down on slip in the rain is only part of what an intelligent chassis can do. The bigger shift is that the car has begun to understand not just what's in front of it, but its own grip, braking power, steering response, and fault state.
Wang Dengfeng, E/E Architecture Manager at Dongfeng Motor's R&D Institute, called this the move "from limbs to cerebellum."
"If the chassis in a conventional car was a limb that took orders, the intelligent chassis of the future has to become a cerebellum — one that understands the vehicle's own state and coordinates multiple actuators on its own."
Even if the driving system plans a route, that route can turn into a plan the car cannot execute unless it knows the grip its tires can find on the current surface, the braking force the car can produce, and how the steering and suspension will respond. For Dongfeng, physical AI means understanding what the car can actually do and translating digital judgment into precise physical action.
Closing the Gap Between Planning and Motion
In a conventional car, propulsion, braking, steering, and suspension were each developed and controlled on their own. The autonomous system would hand down a target trajectory or deceleration, and each device would carry out its assigned command. Information mostly flowed one way, from the driving system down to the chassis.
But there's a gap between the trajectory a system plans and the motion a car can actually deliver. The hard braking and evasive steering possible on dry pavement can't be carried out the same way on snow or in the rain. Tire wear, vehicle load, speed, and grade all change how much a car can accelerate, brake, or turn.
Closing that gap means the driving system and the chassis have to talk to each other. The driving system uses cameras, radar, and map data to tell the chassis what the road ahead and the traffic look like. The chassis reports back the tire's grip, the vehicle's motion state, and how much force each actuator can deliver, along with any faults. The driving system folds that information back into planning a route the car can actually run.
"The chassis needs 'eyes' to read the road and the environment in advance. And the intelligent driving system needs to know the vehicle's own 'physical condition' — how hard it can accelerate, brake, and turn on the current surface — because that's what lets it plan a route the car can actually execute."
If intelligent driving is the eyes that watch the road and the cerebrum that decides where to go, the chassis is the cerebellum that calculates what the car's body can handle. The relationship between the two shifts from a one-way link of command and execution into a two-way collaboration that keeps adjusting plans against physical reality.
Dongfeng frames this integration in three stages. In stage 1.0, built for Level 1 and Level 2, intelligent driving makes the call and the chassis coordinates motion across the X, Y, and Z axes — execution folded inside judgment. Stage 2.0, aimed at Level 3 and Level 4, has the driving system understand the chassis's motion limits while the chassis picks up on driving intent ahead of time and prepares to act — judgment and execution moving into each other's territory. Stage 3.0, aimed at Level 5, is where perception, judgment, and execution stop being separate at all — what Dongfeng calls unity of knowledge and action. An embodied, mobile intelligence that understands not just its surroundings but its own state and capacity, and adapts as conditions change, is the long-term goal Dongfeng has set.
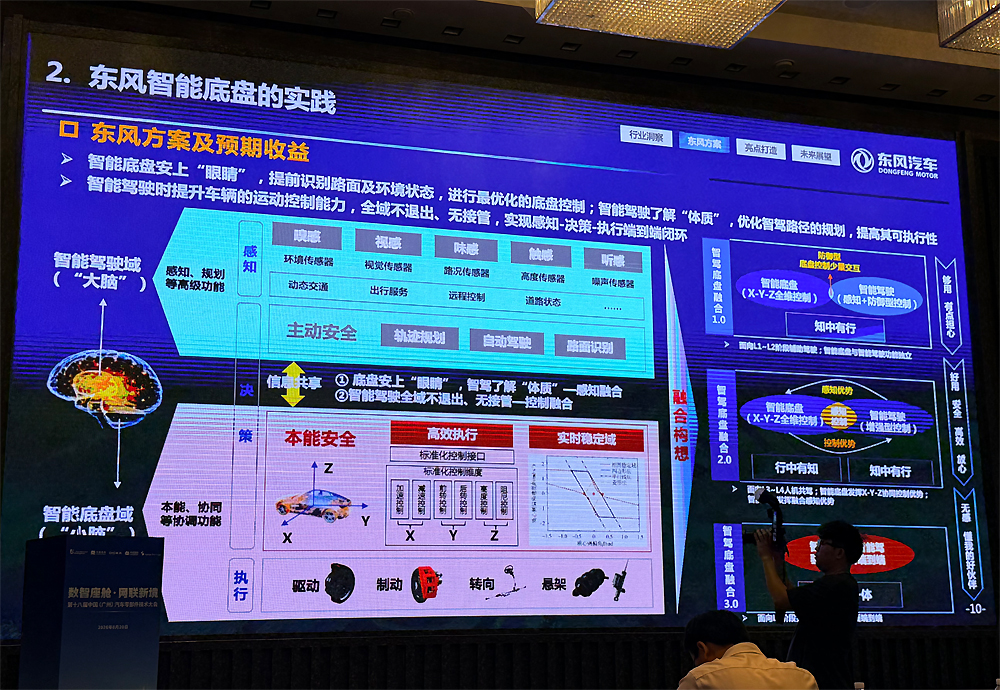
Dongfeng's intelligent chassis concept: the chassis reads the road with its "eyes," while the driving system learns the vehicle's own "physical condition," closing the loop between perception, decision, and execution.
From Reacting to Preparing
Where this shift shows up most directly is in timing. Most safety systems today detect a slipping tire or an unstable body after the fact, then step in. An intelligent chassis prepares the vehicle before it ever reaches the risky surface.
Predictive anti-slip control reads low-friction surfaces — wet roads, snow, ice — in advance. It combines that surface reading with vehicle load, grade, and speed to estimate the friction coefficient, then pre-distributes tractive and braking force across the front and rear axles. If it judges the low-friction condition will persist, it switches into anti-slip mode and keeps correcting its surface estimate against how the wheels actually respond.
Predictive terrain recognition distinguishes irregular ground — speed bumps, gravel, unpaved roads, potholes, bridge joints. Dongfeng uses a Detection Transformer to spot surface anomalies and a Vision Transformer to classify surface type, then combines that with vehicle-dynamics estimation to check what the camera saw against the impact and motion the car actually experienced.
Visual data alone can't be trusted. A surface can look wet and still be dry; a shadow or a patch of old pavement can read as a pothole that isn't there. So the system compares what the camera predicted against what the wheels experienced and revises its next judgment accordingly. Dongfeng's proposed approach forms a closed loop that fuses prediction with observation and verifies perception against the vehicle's physical response.
That feeds into predictive magic-carpet suspension. Before the car reaches a bump or a rough patch, it adjusts the dampers, ride height, and suspension state to cut the impact and keep the body stable. It doesn't stop at reading the road — it turns what it saw into an action that changes ride comfort and stability.
"It's a shift from controlling after something has already gone wrong, to anticipating risk and preparing for it."
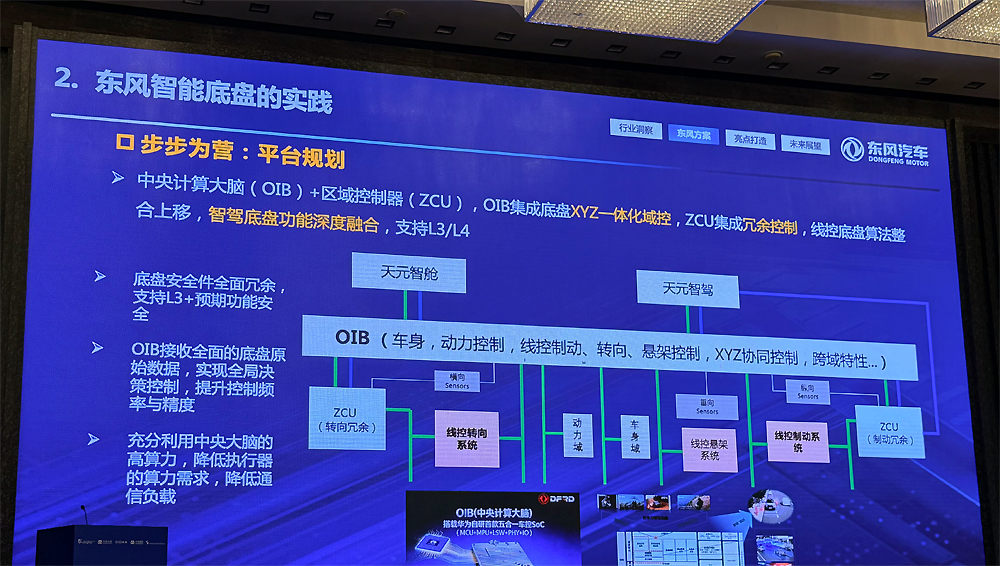
Dongfeng's planned platform pairs OIB, the central computing brain, with zonal control units, or ZCUs. The OIB runs on Huawei's first 5-in-1 vehicle SoC, integrating an MCU, MPU, LSW, PHY, and I/O.
Four Actuators, One Motion
A car's motion on the road doesn't break cleanly into propulsion, braking, steering, and suspension. Acceleration and deceleration happen on the X axis, side-to-side movement on the Y axis, and vertical body motion on the Z axis — all at once, all affecting each other. Dongfeng is pushing integrated X-Y-Z control that coordinates all of this from a central point.
The starting point is turning physical actuators into services. Under a service-oriented architecture, brake-by-wire, steer-by-wire, rear-wheel steering, and suspension are abstracted into independent services that software can call.
Higher-level applications don't need to know how each device works internally. They request a steering angle, a deceleration rate, a ride height, and the relevant chassis device handles the execution. Separating the interface from the hardware's internal implementation means the same motion-control functions can be reused even when the vehicle or the components change. It also becomes possible to allocate propulsion, braking, steering, and suspension based on the vehicle's overall motion rather than controlling each device in isolation.
To do this, Dongfeng is building a platform that pairs a central computing brain, called OIB, with zonal control units, or ZCUs. According to Dongfeng, the OIB runs on the first 5-in-1 vehicle SoC developed by Huawei — a single chip integrating an MCU, MPU, LSW, PHY, and I/O. It's a concrete example of what Dongfeng calls its Tianyuan development principle: "in-house development plus co-creation." The OIB takes in raw data from the body, powertrain, brake-by-wire, steering, and suspension systems to handle integrated X-Y-Z control and cross-domain functions. Control strategies that need heavy computation, along with brand-specific motion characteristics, are also implemented on the OIB.
The ZCUs, by contrast, handle the local execution and redundant control of safety-critical functions like steering and braking. High-level judgment moves to the center, while immediate safety execution stays close to the actuators. It's a division of labor meant to use the central computer's processing power while keeping communication load and the computing demands on individual controllers low — and to keep essential safety functions running even if something goes wrong centrally.
Dongfeng describes this as a combination of brain, heart, and limbs. The OIB and the Tianyuan driving system are the brain and eyes; the Mach Power system is the heart; the by-wire chassis is the limbs. But the chassis doesn't stop at being a precisely moving limb — it also takes on the cerebellum's job of judging the vehicle's state and coordinating the other systems.
AEM(오토모티브일렉트로닉스매거진)
<저작권자 © AEM. 무단전재 및 재배포 금지>
.jpg) [ICS] 10BASE-T1S 무료 교육 (매월 둘째 주 금요일)